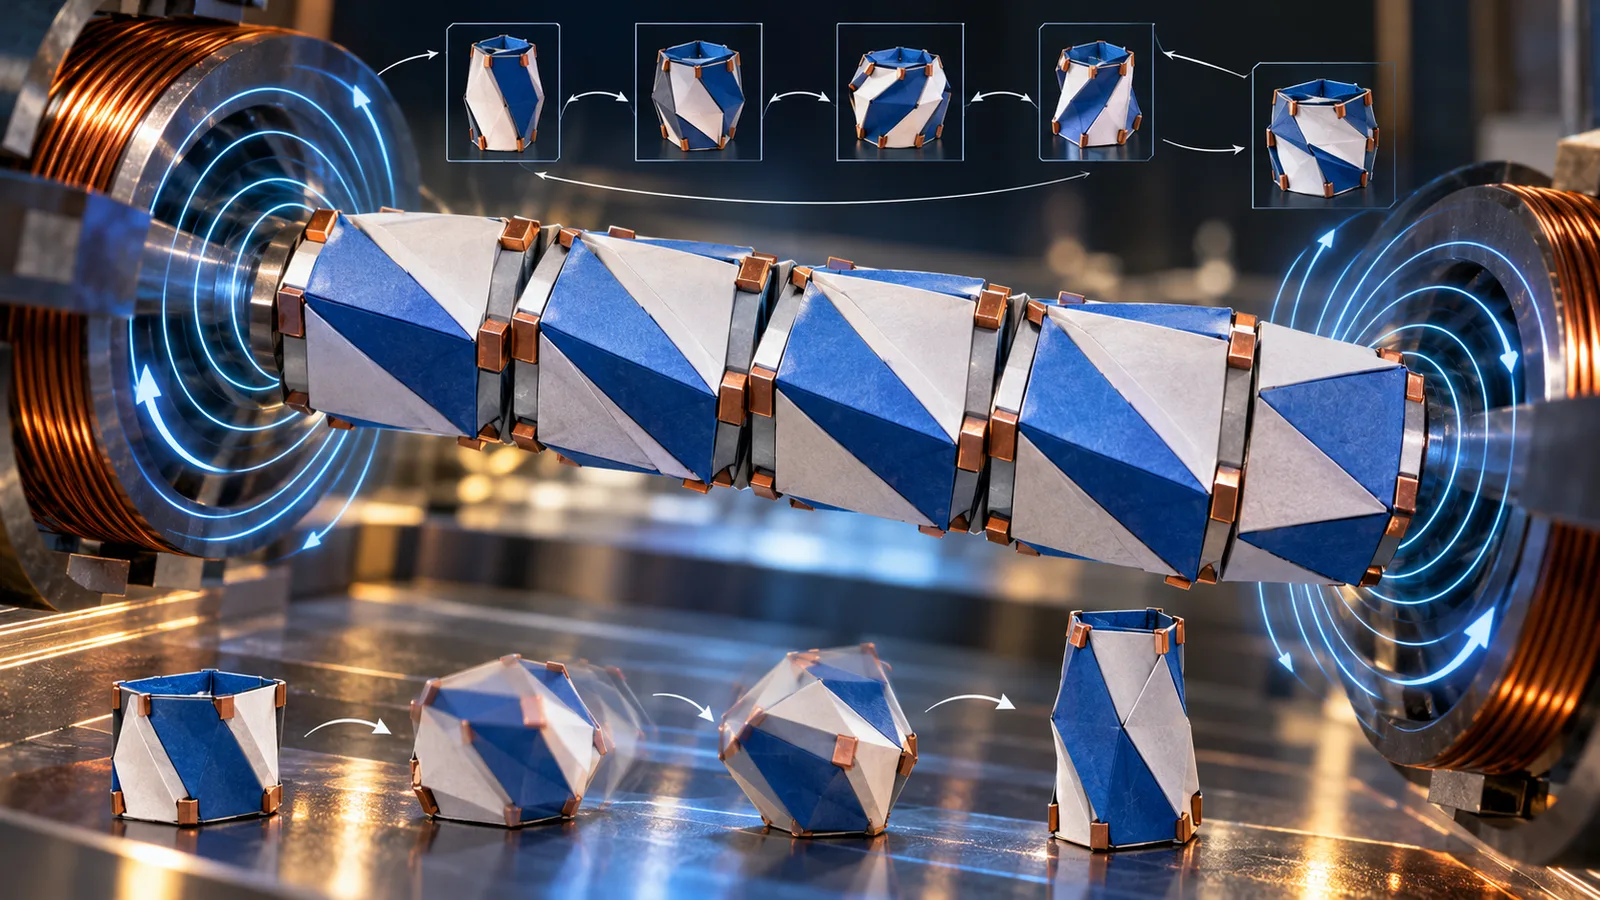
Origami state machine with time-varying magnetic fields.
Achieving reliable, remote control over multiple stable states in modular systems remains a challenge due to the coupling between modules and history-dependent transitions. Here, we present magnetic origami state machines that enable deterministic navigation from any unknown initial state to any target state under magnetic actuation. By assuming mutually distinct energy barriers in modular Kresling origami assemblies, we realize fully accessible transition graphs with scalable state spaces. Guid
Achieving reliable, remote control over multiple stable states in modular systems remains a challenge due to the coupling between modules and history-dependent transitions. Here, we present magnetic origami state machines that enable deterministic navigation from any unknown initial state to any target state under magnetic actuation. By assuming mutually distinct energy barriers in modular Kresling origami assemblies, we realize fully accessible transition graphs with scalable state spaces. Guided by the graph associated to the state machine, a rotating magnetic field induces a universal reset that autonomously drives the system to a known equilibrium state from arbitrary states without sensing or feedback, while pulsed magnetic inputs further enable programmable transitions to any target state via prescribed actuation sequences. A reduced-order Lagrangian mechanics model predicts snap-through dynamics across reset, stepwise programming (between graph nodes), and shortcuts (by adapting pulse magnitude and orientation) where inertia triggers simultaneous multicell transitions with a single pulse. These results establish a general framework for programmable magneto-mechanical state machines with autonomous state reset and full state-space control.